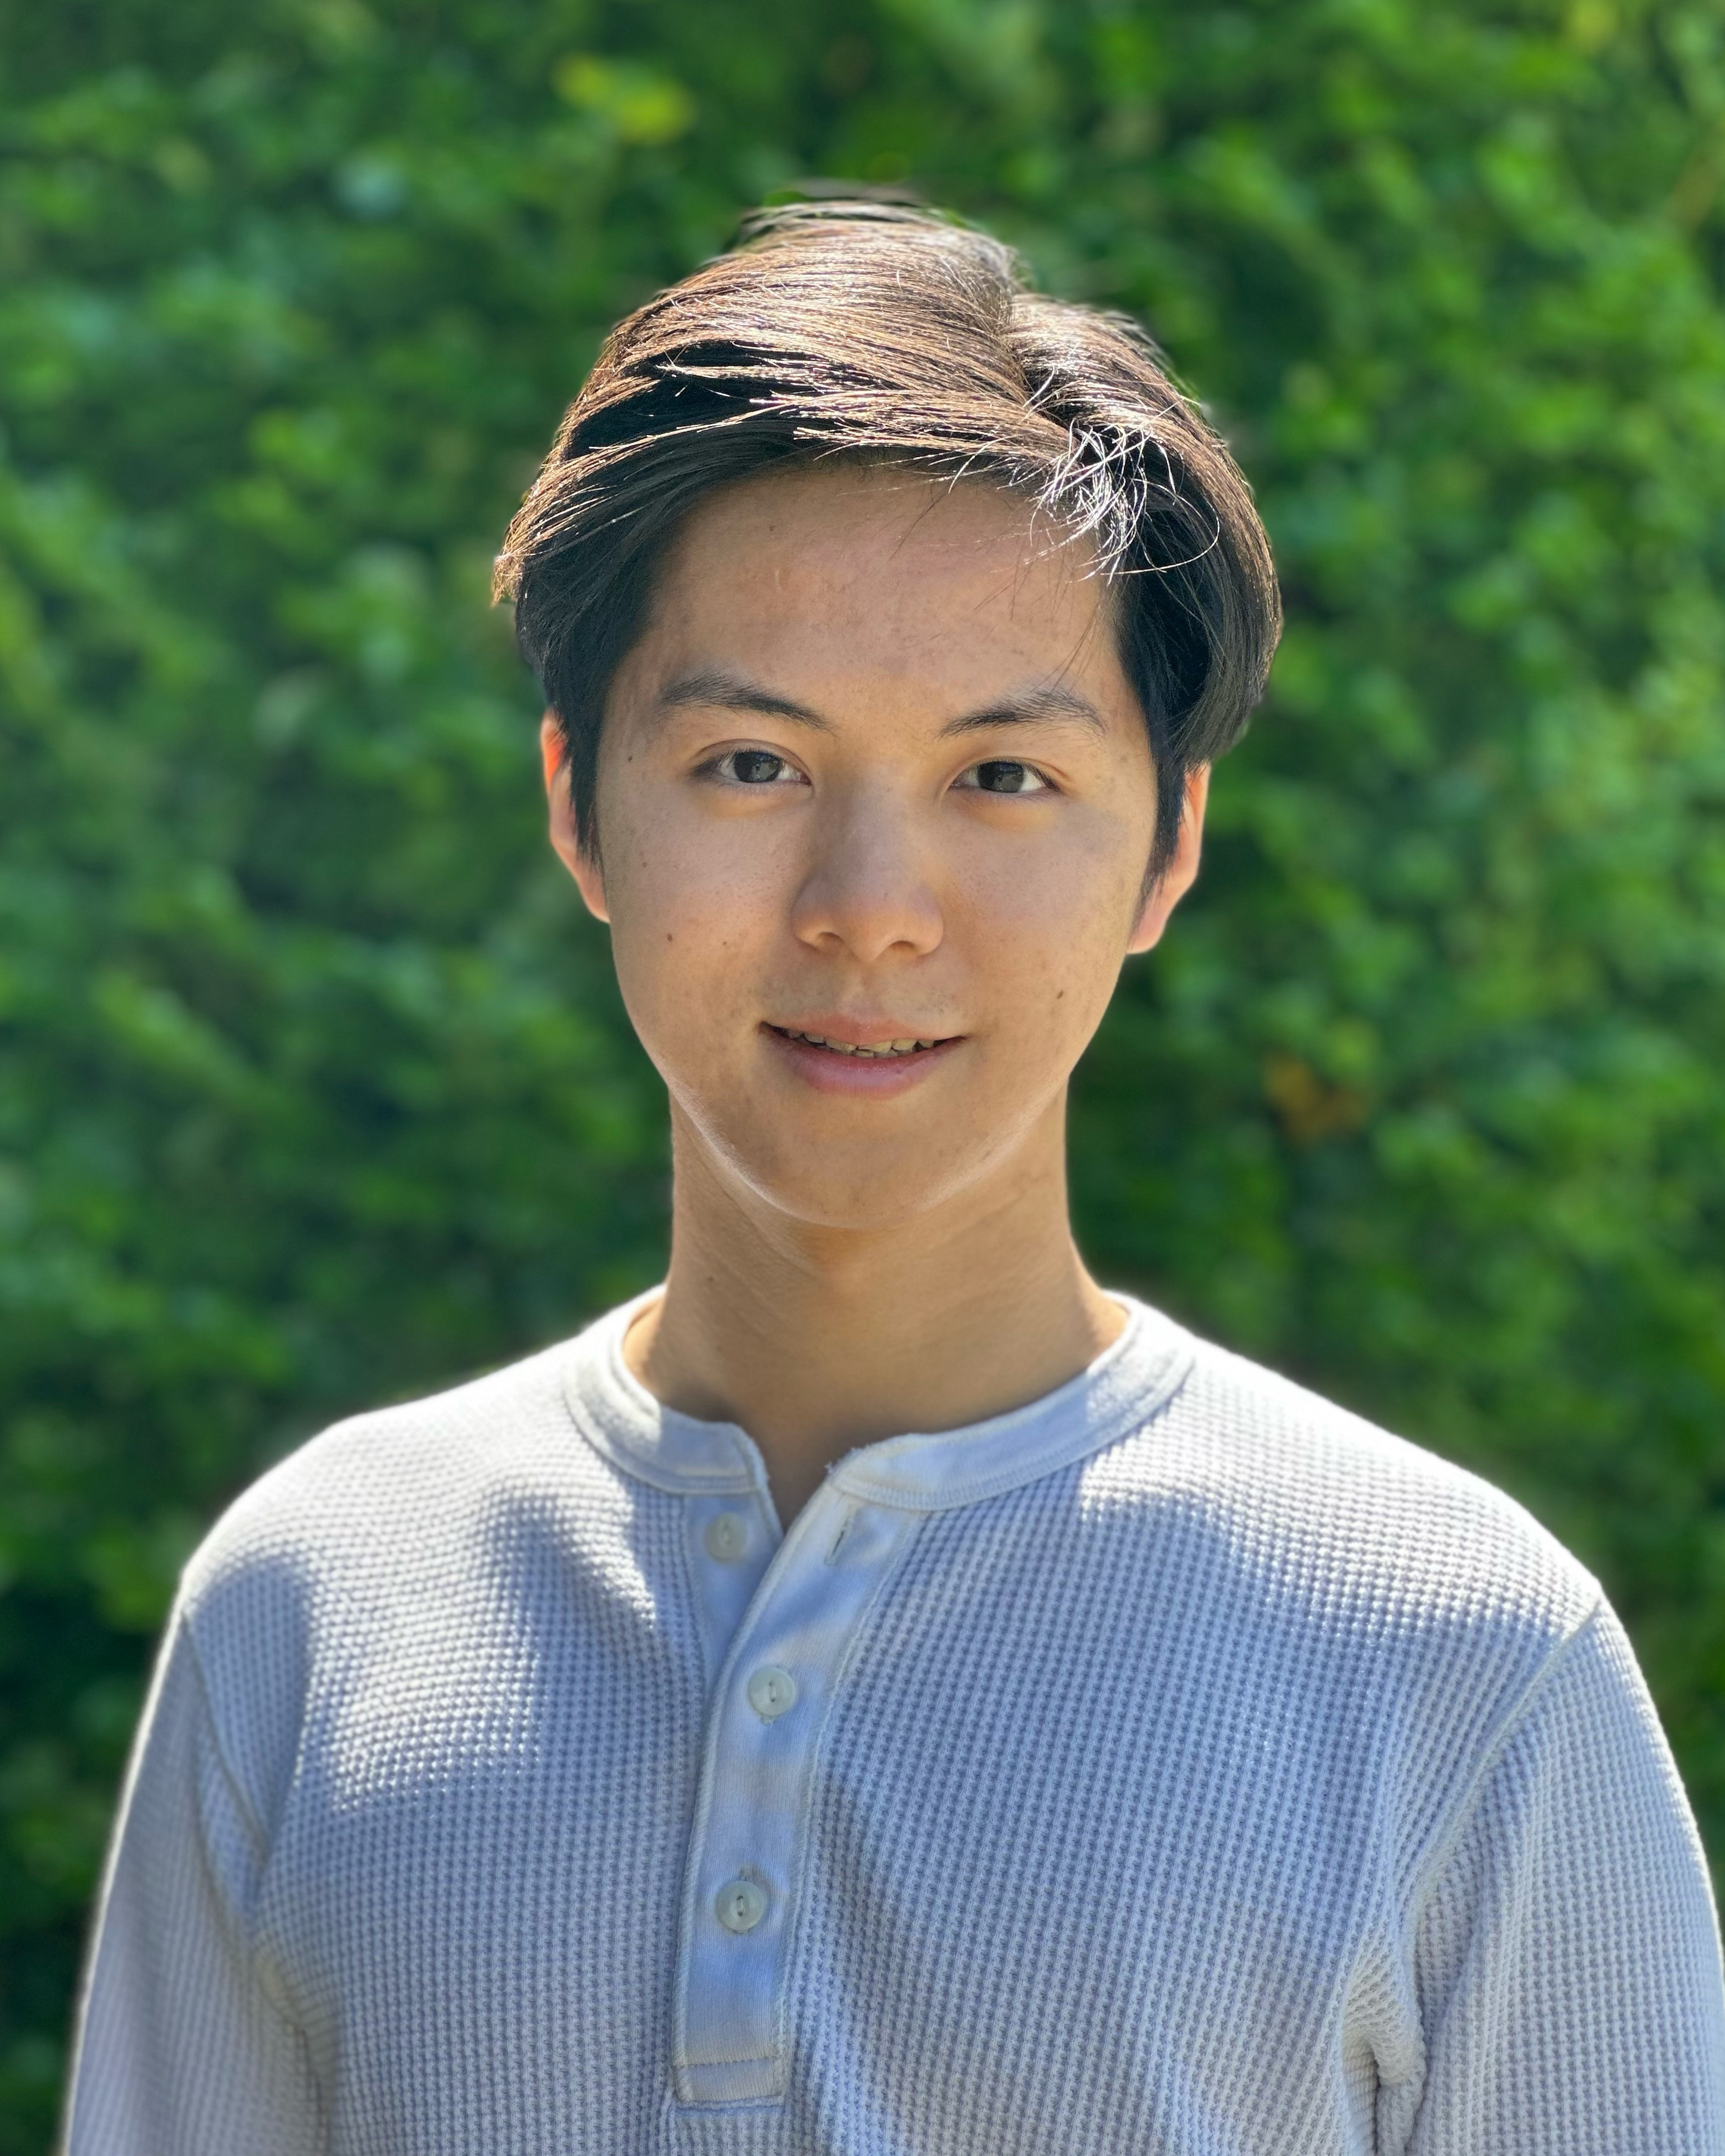
Charles XuI am currently a PhD student at UC Berkeley, advised by professor Sergey Levine. I recently interned at Physical Intelligence, where I built a system for real-world online RL with VLA's. Before this, I finished my undergrad at UC Berkeley in EECS in May 2024, where I also conducted research with professor Sergey Levine. I've also had the pleasure of working with Stefan Schaal from Intrinsic. My research interest is learning from real-world experience through on-robot online reinforcement learning for scalable and deployable robot systems. xuc [at] berkeley [dot] edu / GitHub / Google Scholar |
|

|
Test-Time Gradient Guidance of Flow Policies in Reinforcement LearningZhiyuan Zhou, Andy Peng, Charles Xu, Qiyang Li, Jost Tobias Springenberg, Kevin Frans, Sergey Levine Conference on Neural Information Processing Systems (NeurIPS), 2026 website / paper / code |
|
π0.7: a Steerable Model with Emergent CapabilitiesPhysical Intelligence Team Conference on Robot Learning (CoRL), 2026, Oral (top 1%) website / paper |
|
RL Token: Bootstrapping Online RL with Vision-Language-Action ModelsCharles Xu, Jost Tobias Springenberg, Michael Equi, Ali Amin, Adnan Esmail, Sergey Levine, Liyiming Ke Conference on Robot Learning (CoRL), 2026, Oral (top 1%) website / paper |
|
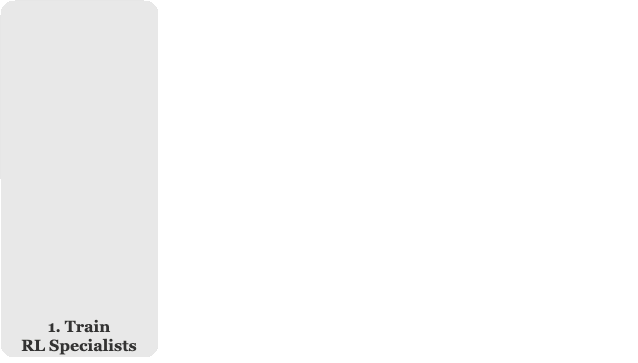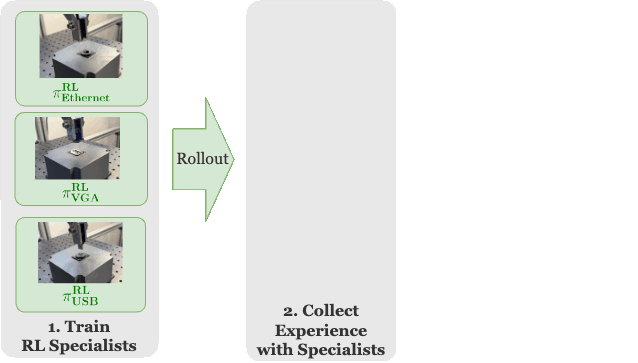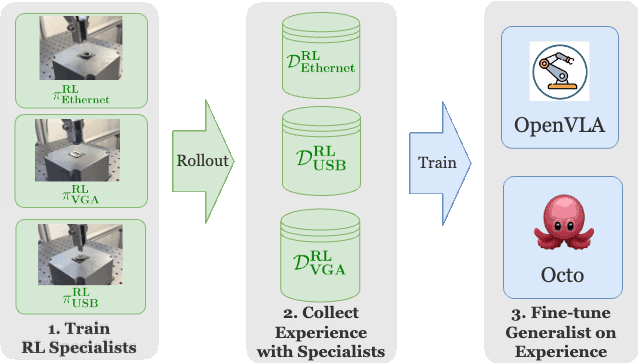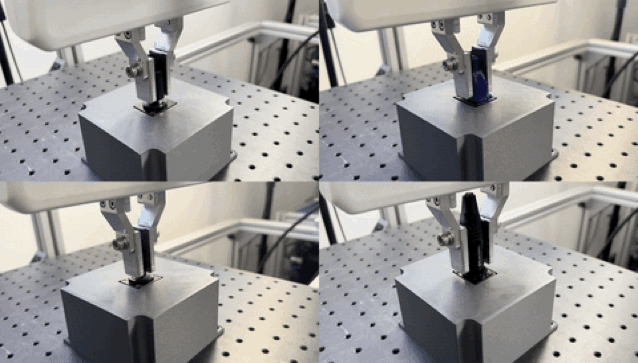
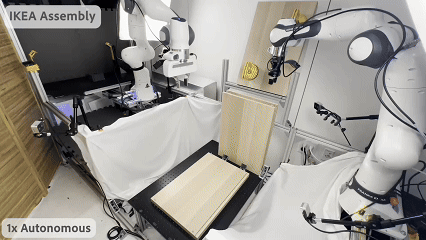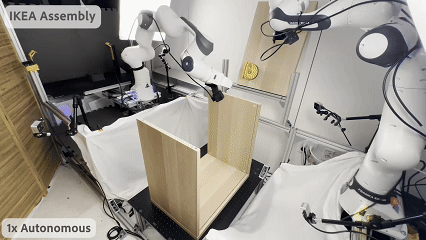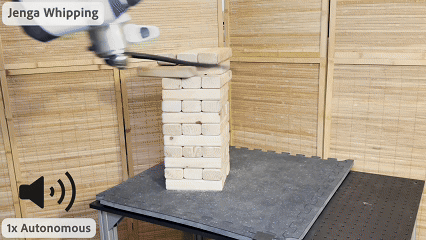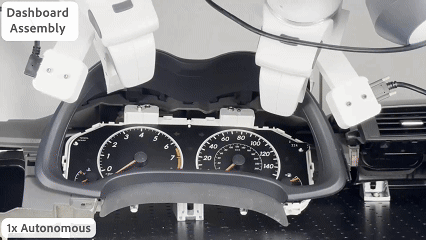
RLDG: Robotic Generalist Policy Distillation via Reinforcement LearningCharles Xu, Qiyang Li, Jianlan Luo, Sergey Levine Robotics: Science and Systems (RSS), 2025 website / paper |
|
Precise and Dexterous Robotic Manipulation via Human-in-the-Loop Reinforcement LearningJianlan Luo†, Charles Xu†, Jeffrey Wu, Sergey Levine Science Robotics, 2025 website / paper |
|
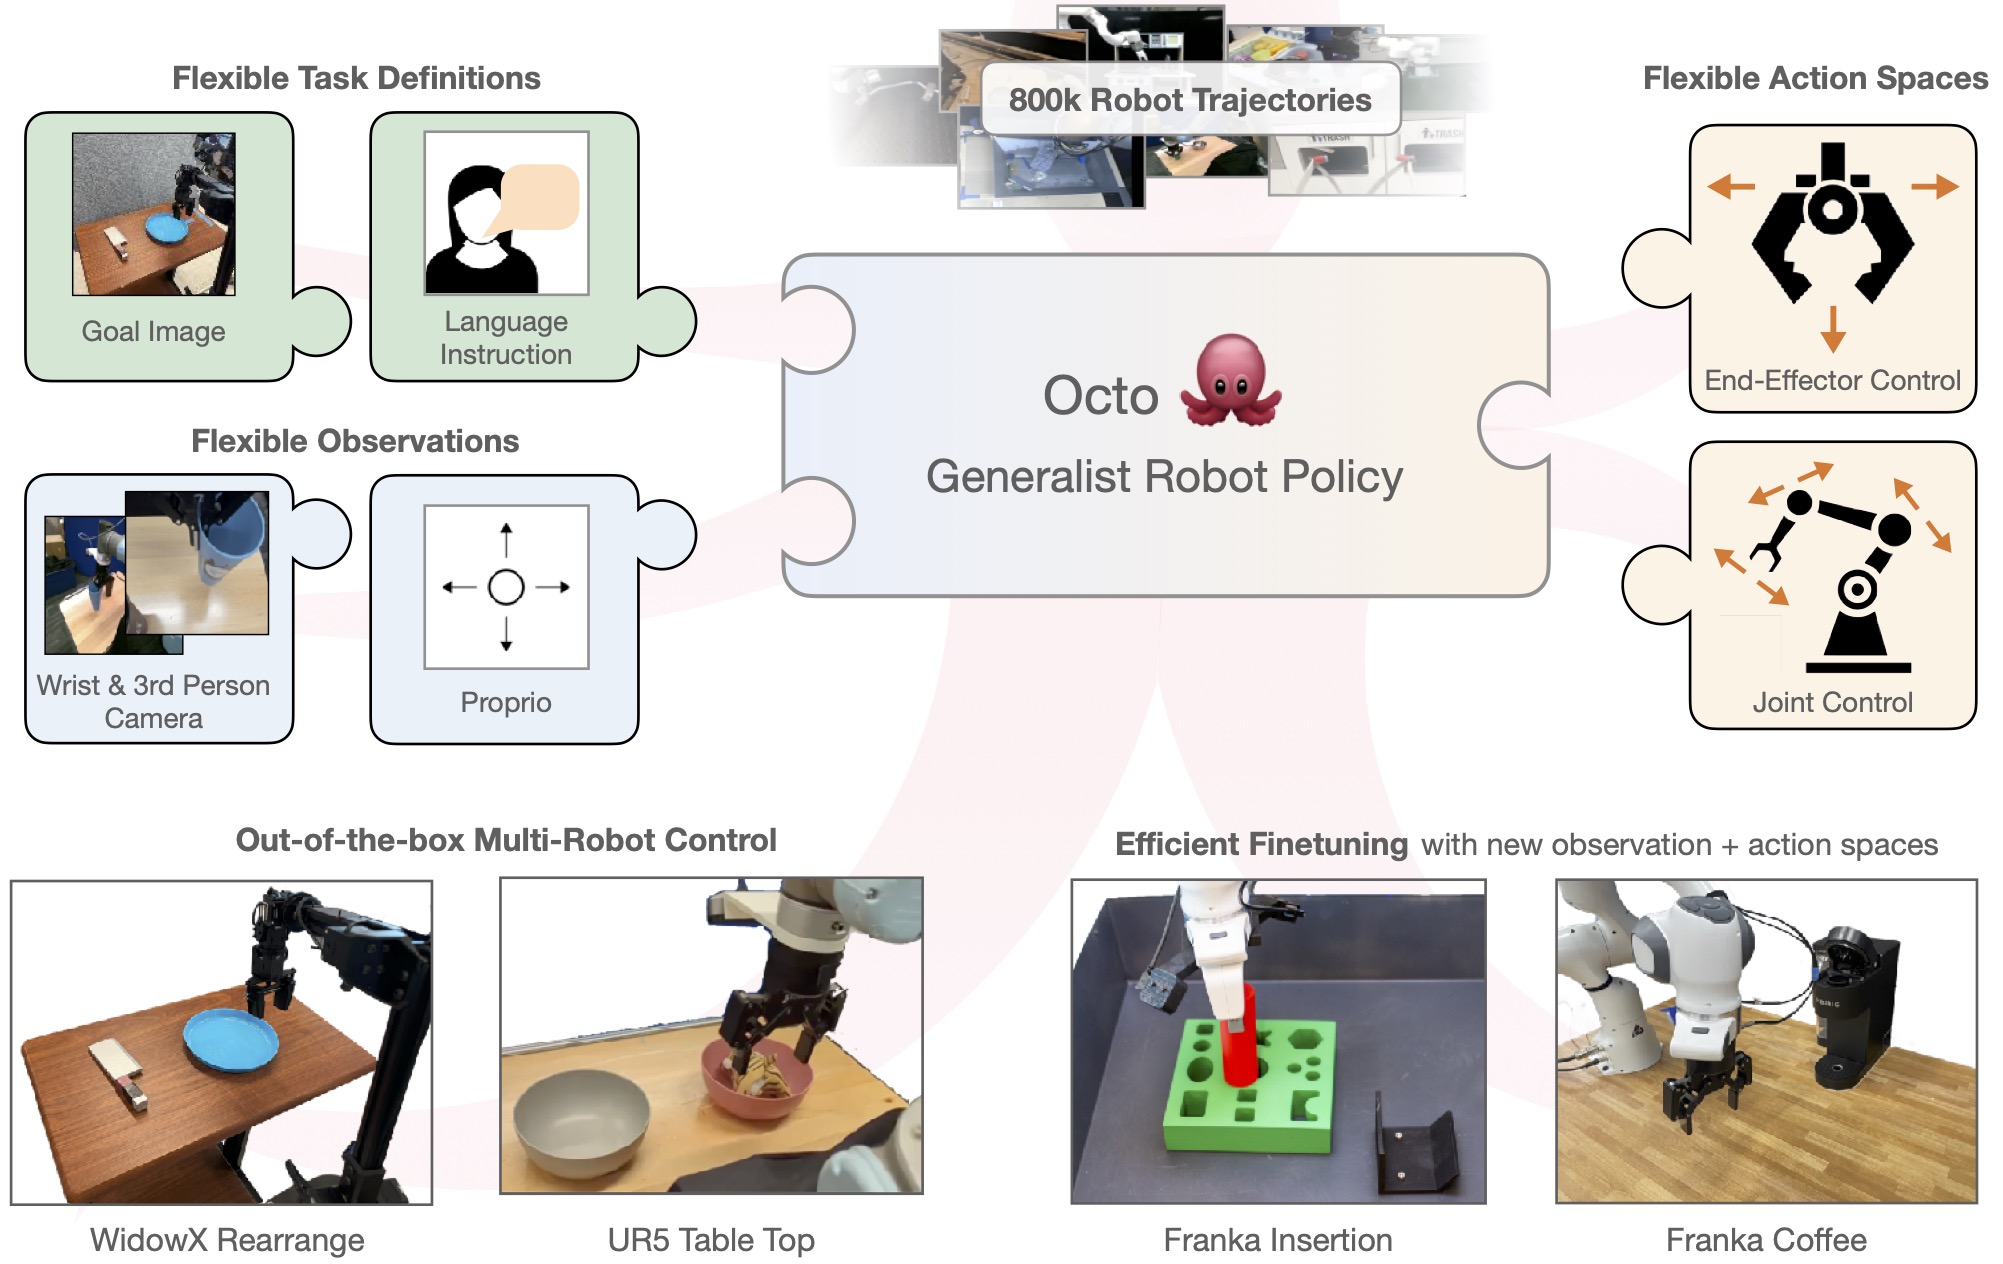
Octo: An Open-Source Generalist Robot PolicyDibya Ghosh*, Homer Walke*, Karl Pertsch*, Kevin Black*, Oier Mees*, Sudeep Dasari, Joey Hejna, Tobias Kreiman, Charles Xu, Jianlan Luo, You Liang Tan, Dorsa Sadigh, Chelsea Finn, Sergey Levine Robotics: Science and Systems (RSS), 2024 website / paper / code |
|
SERL: A Software Suite for Sample-Efficient Robotic Reinforcement LearningJianlan Luo*, Zheyuan Hu*, Charles Xu, Siri Gadipudi, Archit Sharma, Rehaan Ahmad, Stefan Schaal, Chelsea Finn, Abhishek Gupta, Sergey Levine International Conference on Robotics and Automation (ICRA), 2024 website / paper / video / code |
|
Open X-Embodiment: Robotic Learning Datasets and RT-X ModelsOpen X-Embodiment Collaboration International Conference on Robotics and Automation (ICRA), 2024, Best Paper Award website / paper / code / data |
|
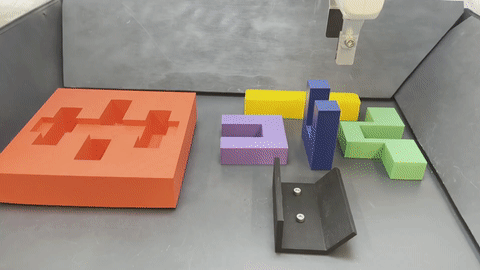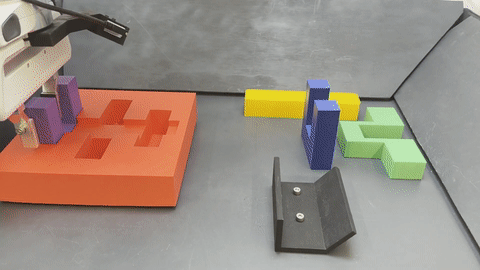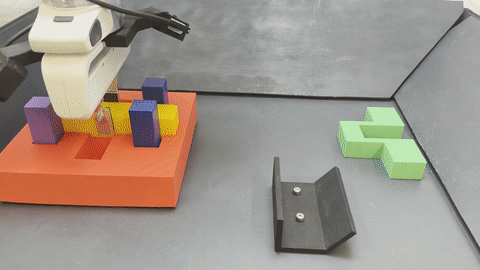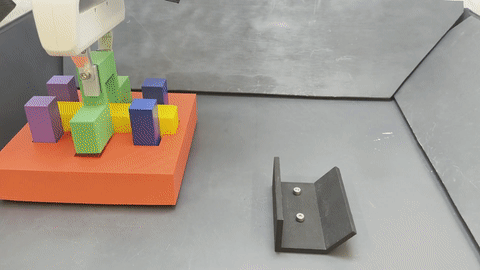
FMB: A Functional Manipulation Benchmark for Generalizable Robotic LearningJianlan Luo*, Charles Xu*, Fangchen Liu, Liam Tan, Zipeng Lin, Jeffrey Wu, Pieter Abbeel, Sergey Levine The International Journal of Robotics Research (IJRR) website / paper / video / code / data |
|
Multi-Stage Cable Routing through Hierarchical Imitation LearningJianlan Luo*, Charles Xu*, Xinyang Geng, Gilbert Feng, Kuan Fang, Liam Tan, Stefan Schaal, Sergey Levine Transactions on Robotics (T-RO), 2024 website / paper / video / code / data |
|
EECS C106A/206A: Introduction to RoboticsLab Assistant: Fall 2023 |
|
CS 189: Introduction to Machine LearningTutor: Spring 2023 |
|
Design and source code from Jon Barron's website |